
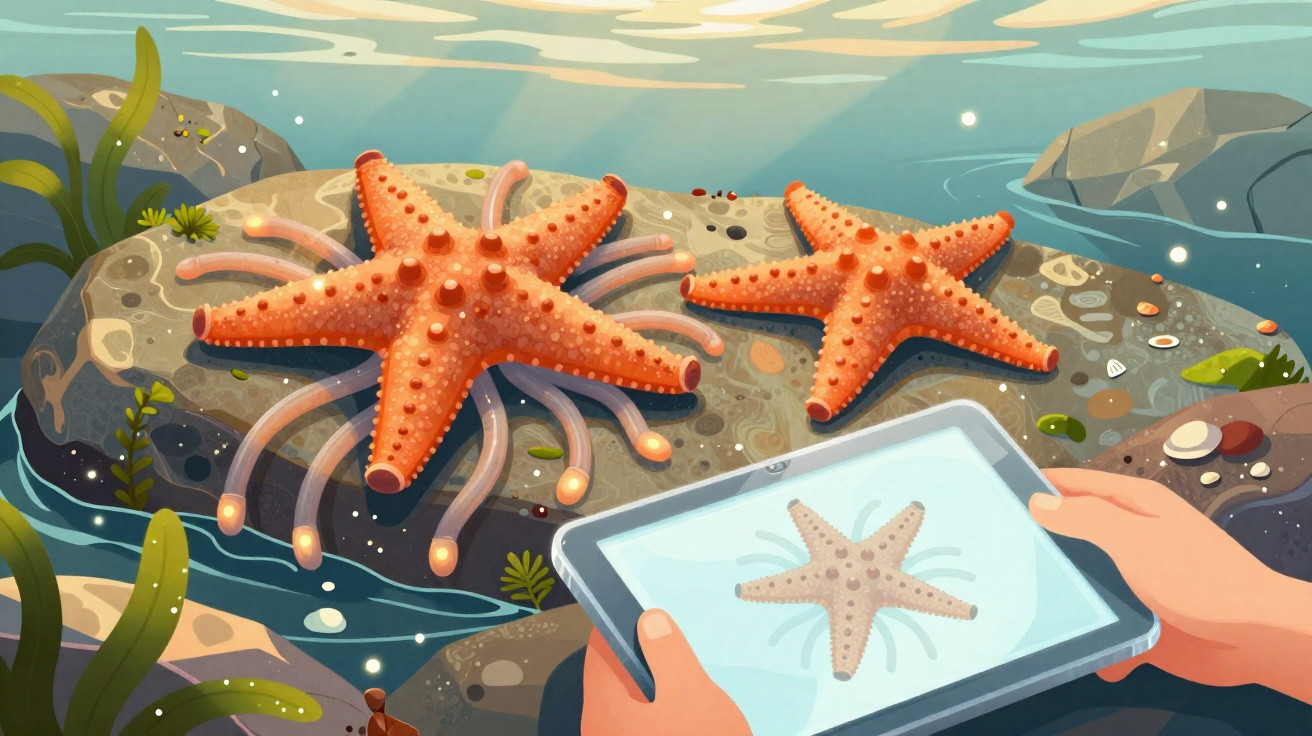
Sea stars may appear placid and uncomplicated, but the way they move is remarkably intricate. Rather than using a centralised brain to control motion, they coordinate hundreds of minute tube feet.
As the animal crosses irregular terrain, every foot attaches, pulls and releases independently. This movement is slow, yet notably effective.
Researchers at USC’s Kanso Bioinspired Motion Lab believe this “brainless” collaboration is precisely what makes sea stars compelling for robotics.
In a recent paper, the team explains how sea stars achieve coordinated movement through local decisions made by individual tube feet.
Tube feet respond to local forces
The principle is straightforward: each tube foot changes its grip according to local mechanical strain – the force acting on it. Rather than awaiting commands, a foot reacts directly to the conditions at its own location.
The team tested this approach with collaborators from UC Irvine and the University of Mons in Belgium.
They created a 3D-printed “backpack” for a sea star, then added and removed loads to alter the animal’s weight.
“Together with Associate Professor Sylvain Gabriele and graduate student Amandine Deridoux at the SYMBIOSE Lab, we designed a special 3D-printed “backpack” for the sea star,” said Eva Kanso, the director of the Kanso Lab.
“By loading and unloading the backpack, we could observe and measure how each tube foot responded to the added weight.”
Their observations showed that the feet did not wait for an overall signal – each one responded on its own.
“From the outset, we hypothesized that sea stars rely on a hierarchical and distributed control strategy, in which each tube foot makes local decisions about when to attach and detach from the surface based on local mechanical cues, rather than being directed by a central controller,” Kanso said.
Simple rules create whole-body coordination
The USC researchers developed a mathematical model demonstrating how this local “if it feels like this, do that” response can produce coordinated locomotion – because the feet are mechanically connected through the body.
“At USC, we developed a mathematical model showing how simple, local control rules, coupled through the mechanics of the body, can give rise to coordinated, whole-animal locomotion,” Kanso explained.
A sea star requires no overarching plan. The physics of its body helps combine many small local decisions into movement that appears organised.
“We also conducted experiments in which we turned the sea star upside-down – the morphology of the tube feet allows the sea star to continue to move,” said Kanso.
For a human, being upside-down would signal an emergency requiring every available hand. For a sea star, it simply means different forces are acting on different feet.
There is no single nervous “panic message” sent across the body. Instead, every tube foot handles its own circumstances.
Effective movement without a brain
This arrangement brings a major benefit: robustness. Should several tube feet fail or lose contact, the sea star does not stop moving. The remaining feet continue to adjust because control is distributed.
This type of inherent redundancy is exactly what would be useful in a robot that might be overturned, made to carry an additional load, lose grip, or work where communications are restricted or unreliable.
The researchers say the findings are directly relevant to soft robots and multi-contact robots – machines that must crawl, climb or grip in difficult environments, including underwater, on vertical surfaces or even on other planets.
In such situations, depending on one “mission control” signal or a perfectly synchronised controller may be hazardous.
Ultimately, sea stars demonstrate that speed can be exchanged for adaptability while still producing unexpectedly effective movement, even without a central brain directing events.
“Together, these findings demonstrate that sea stars adapt their locomotion to changing mechanical demands by modulating tube foot-substrate interactions, revealing a robust decentralized control strategy in a brainless organism and highlighting general principles of distributed control in biology and soft robotics,” the researchers concluded.
Comments
No comments yet. Be the first to comment!
Leave a Comment